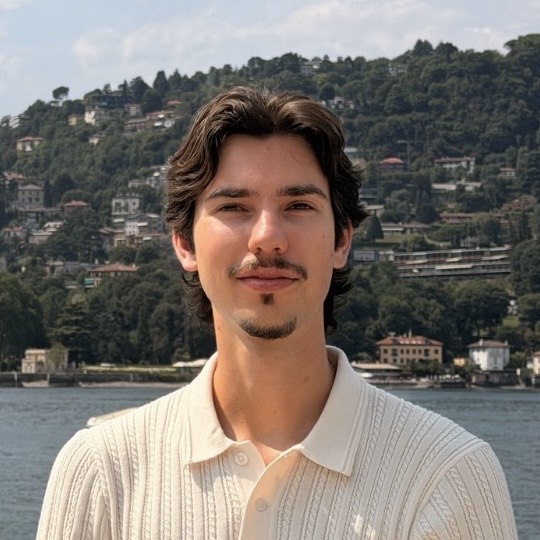
I'm Kaloyan Draganov, a Computer Engineering and Computer Science student at Northeastern University passionate about how robots perceive the world and turn that understanding into reliable actions.
I started in FIRST Robotics, where I spent four years building and programming competition robots. As Technical Captain, I worked across mechanical, electrical, and software systems. I developed Java-based real-time control software using PID feedback and kinematics, and combined IMU odometry with camera-based AprilTag detections for field-relative localization and autonomous path following.
At Northeastern, I joined the Mars Rover Team and now serve as Autonomous Software Lead. I implemented an extended Kalman filter in ROS 2 that combines GNSS with frame-transformed IMU odometry from our ZED camera for localization. I also developed a holonomic MPPI local planner for obstacle avoidance, along with noisy-sensor simulation and ground-truth visualization tools to validate the autonomy stack before field testing.
I also work on the embedded side of robotics. For the rover, I migrated the drivetrain from PWM to CAN and developed ROS 2/SocketCAN control for Kraken X44 motors. With AerospaceNU, I developed flight-control and telemetry software and integrated sensors over SPI, I²C, and UART.
Last co-op cycle, I worked full-time as the first Embedded Systems Co-op at Re:Build Fikst. There I developed STM32 firmware in C with FreeRTOS, wrote I²C drivers, and brought up medical-device PCBs. I also owned two production automation projects: an EEPROM programming station and an end-of-line PCB test system used to validate manufactured hardware.
These experiences have given me a broad view of autonomous systems, from perception and planning to low-level hardware control. I'm seeking a January–June 2027 co-op in robotics perception, controls, autonomy, or embedded systems.
Technical Skills
ROS 2
Sensor Fusion
Motion Planning
Computer Vision
PID Control
C / C++
Python
CAN
STM32
FreeRTOS
Linux / Ubuntu
SPI
I2C
PyTorch
MATLAB
FPGA
Java